CoPRE is now available on arXiv.
Computer Science undergraduate · Robotics research
Yuxiao Zhu 朱煜肖
I am interested in building robots that understand the physical world, reason about tasks, and act reliably to help people. My work spans contact sensing for manipulation and reasoning and planning for multi-robot systems. Looking ahead, I hope to explore how learning through physical interaction can connect perception, reasoning, and action.
Embodied AI
Robot Perception
Reasoning and Planning
Contact-Rich Manipulation
News
New RSS workshop abstract on belief-guided contact exploration under noisy proprioception.
Melding LLM and temporal logic is on arXiv and under review at npj Robotics.
Presenting DEXTER-LLM at IROS 2025 in Hangzhou.
Research
How can robots understand the physical world and connect reasoning with reliable action?
My work spans contact sensing for manipulation and reasoning and planning for multi-robot systems. I am interested in exploring how learning through physical interaction can connect perception, reasoning, and action.
Action-Relevant Models
Representing incomplete state, predicting action outcomes, and focusing on world models that are useful for action.
Reliable Action under Uncertainty
Planning and coordination when perception, communication, and environment models are incomplete.
Human-Centered Robot Intelligence
Language-guided planning, human-in-the-loop reasoning, and interpretable robot behavior that supports human goals.
Contact-Rich Manipulation
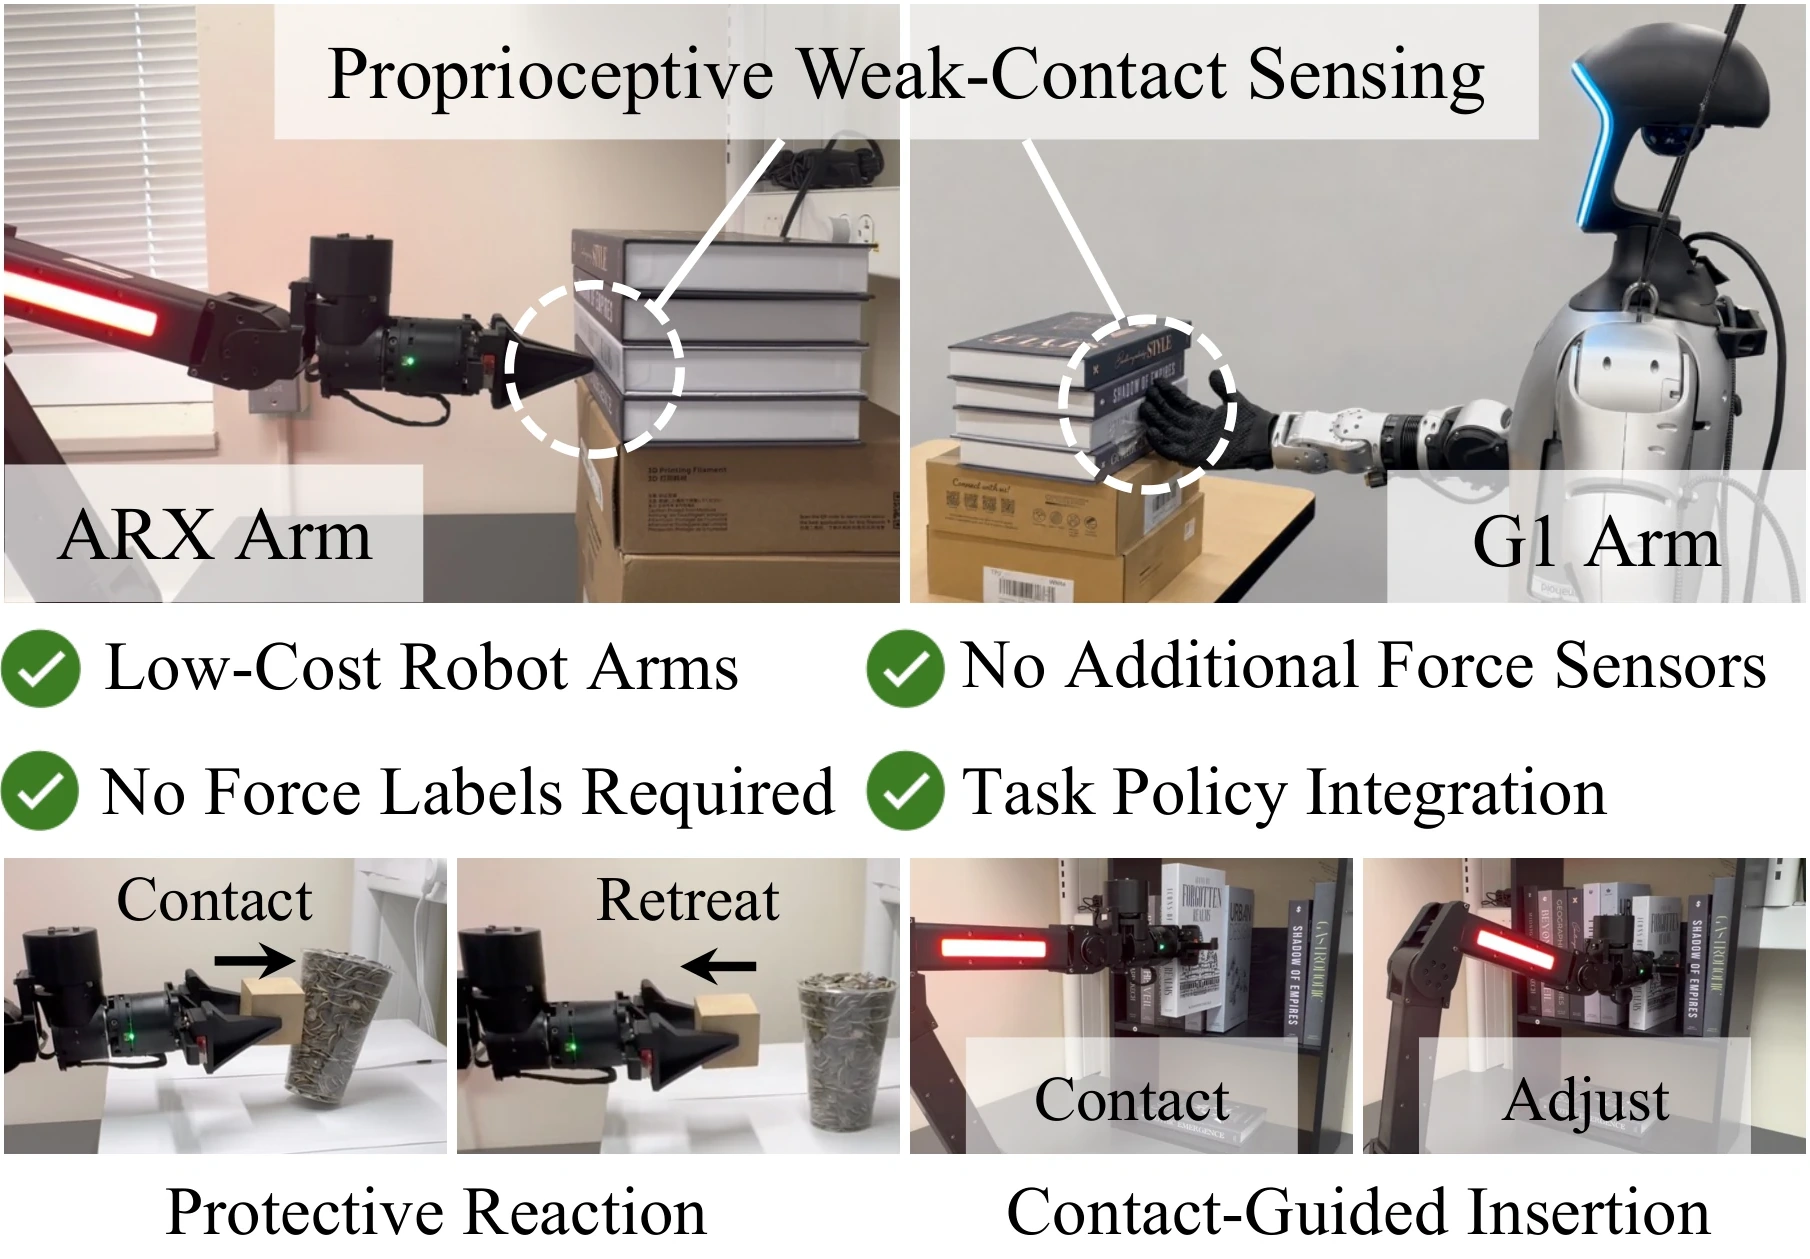
Using contact and proprioception as evidence for manipulation in cluttered, partially observed physical environments.
Selected Publications
Selected papers
5 selected works

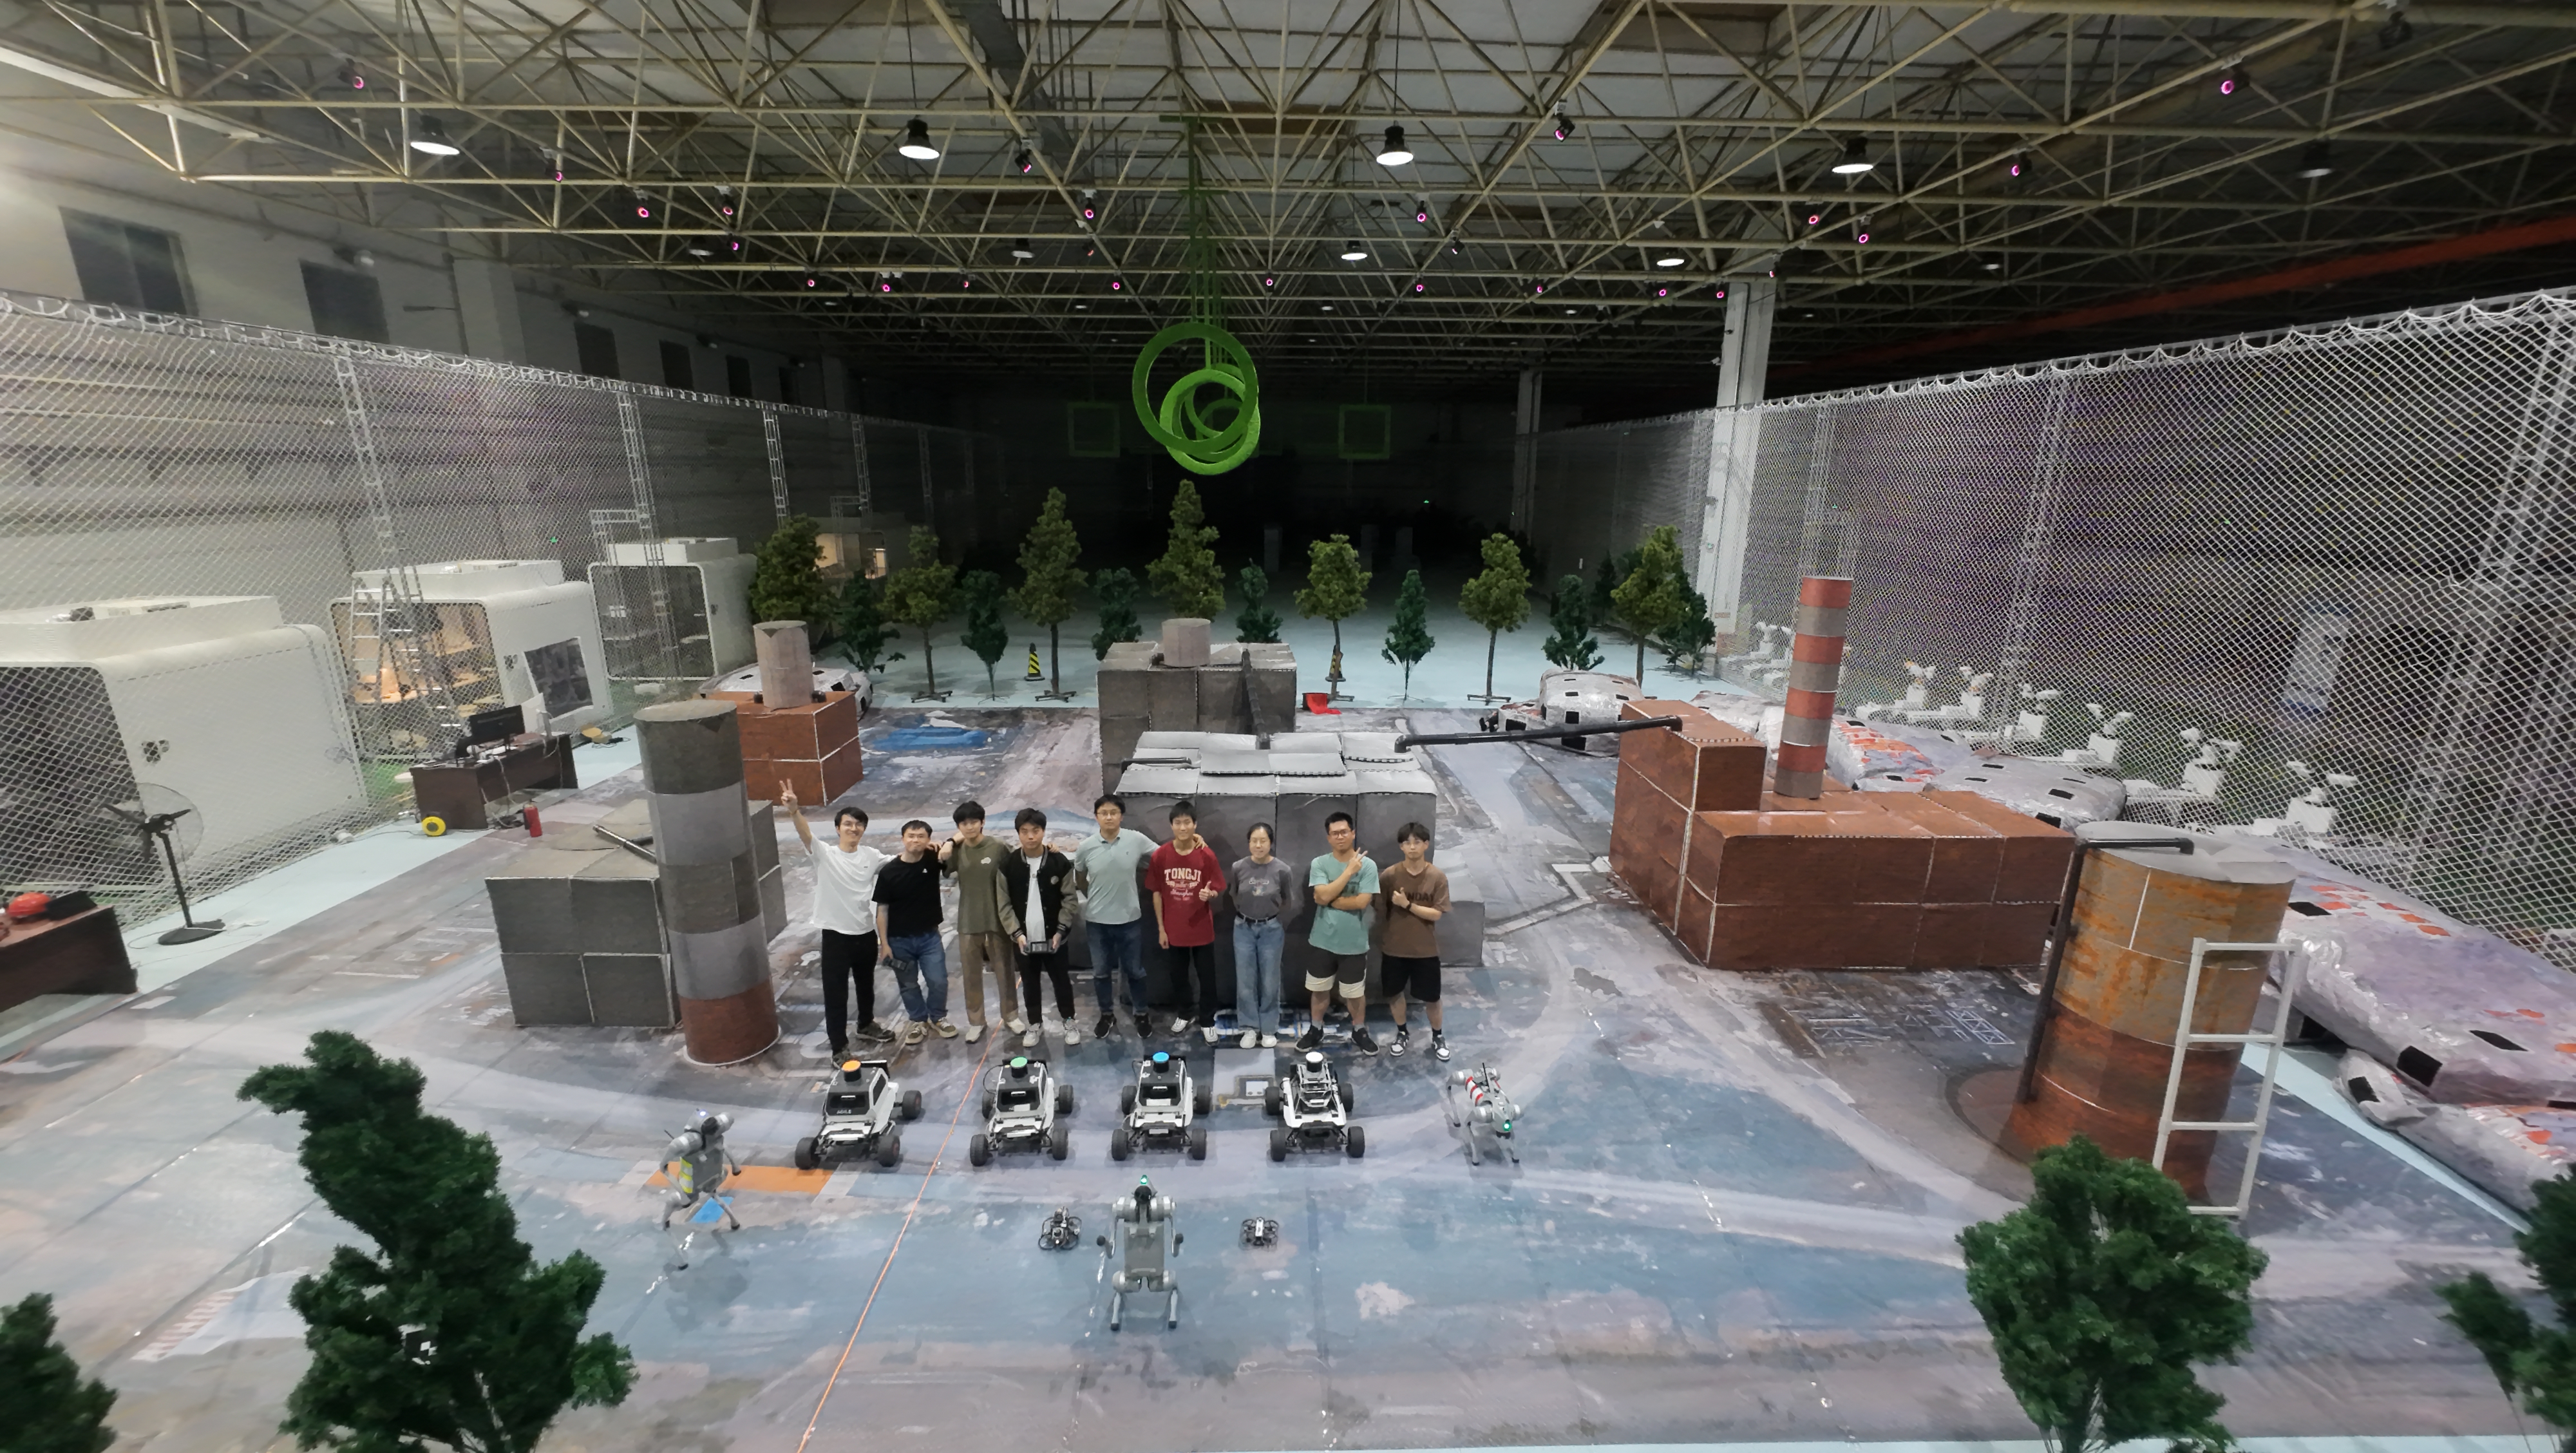
DEXTER-LLM: Dynamic and Explainable Coordination of Multi-Robot Systems in Unknown Environments via Large Language Models
Integrates LLM-based multi-stage reasoning, optimization-based task assignment, and adaptive human-in-the-loop verification for dynamic multi-robot task planning in unknown environments.
@INPROCEEDINGS{11247301,
  author={Zhu, Yuxiao and Chen, Junfeng and Zhang, Xintong and Guo, Meng and Li, Zhongkui},
  booktitle={2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  title={DEXTER-LLM: Dynamic and Explainable Coordination of Multi-Robot Systems in Unknown Environments via Large Language Models},
  year={2025},
  pages={10182-10189},
  doi={10.1109/IROS60139.2025.11247301}
}

SLEI3D: Simultaneous Exploration and Inspection via Heterogeneous Fleets under Limited Communication
A planning and coordination framework for heterogeneous multi-robot systems performing simultaneous 3D exploration, inspection, and real-time reporting under limited communication.
@ARTICLE{11298198,
  author={Chen, Junfeng and Zhu, Yuxiao and Zhang, Xintong and Luo, Bin and Guo, Meng},
  journal={IEEE Transactions on Automation Science and Engineering},
  title={SLEI3D: Simultaneous Exploration and Inspection via Heterogeneous Fleets Under Limited Communication},
  year={2026},
  volume={23},
  number={},
  pages={2339-2360},
  keywords={Robots;Robot kinematics;Inspection;Protocols;Collaboration;Three-dimensional displays;Planning;Collision avoidance;Sensors;Safety;Heterogeneous multi-robot system;3D exploration;collaborative task planning;intermittent communication},
  doi={10.1109/TASE.2025.3643166}
}
CoCoPlan: Adaptive Coordination and Communication for Multi-robot Systems in Dynamic and Unknown Environments
Co-optimizes collaborative task planning and intermittent communication for multi-robot systems in dynamic environments under limited connectivity.
@ARTICLE{11361077,
  author={Zhang, Xintong and Chen, Junfeng and Zhu, Yuxiao and Luo, Bing and Guo, Meng},
  journal={IEEE Robotics and Automation Letters},
  title={CoCoPlan: Adaptive Coordination and Communication for Multi-Robot Systems in Dynamic and Unknown Environments},
  year={2026},
  volume={11},
  number={3},
  pages={3270-3277},
  doi={10.1109/LRA.2026.3656769}
}
Experience
Research training

Undergraduate Researcher
Undergraduate research with Prof. Xianyi Cheng on belief-guided contact exploration and robot manipulation with proprioceptive sensing.

Visiting Undergraduate Researcher
Conducted continuous hybrid online and in-person research with Prof. Meng Guo on multi-agent collaboration, LLM-based robot coordination, and heterogeneous multi-robot planning.
Education
Academic background
B.S. in Computer Science

B.S. in Computer Science
Talks
Recent and upcoming presentations
DEXTER-LLM: Dynamic and Explainable Coordination of Multi-Robot Systems in Unknown Environments via Large Language Models
IROS 2025 Conference, Hangzhou International Expo Center, Hangzhou, China.
Presentation on dynamic task planning in unknown environments via LLM-based reasoning, optimization-based task assignment, and adaptive human-in-the-loop verification.
